

Advanced motion control
An economic multi-axis motion controller and high level software development environment from ABB is helping Rollem – a specialist print machinery manufacturer – to rapidly evolve its modular finishing system.
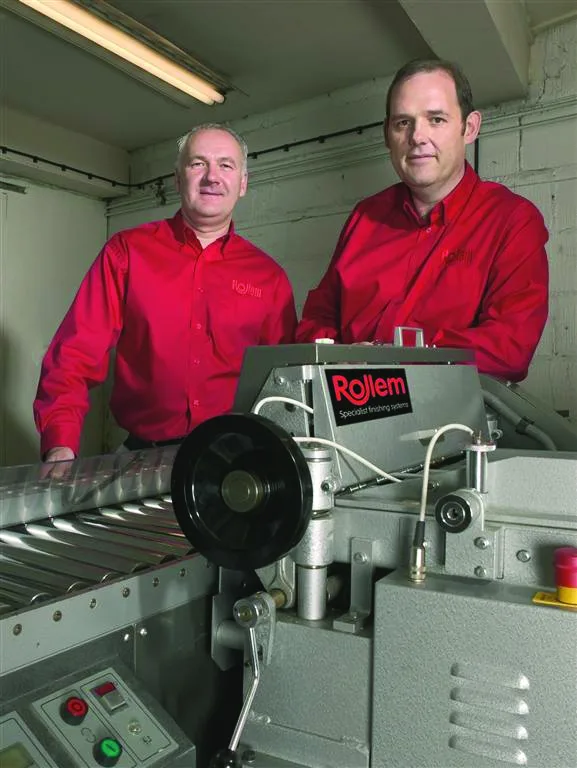
The motion architecture has made it easy to add another peripheral to the Rollem’s print finishing equipment range – a stacking unit that collects and groups products such as business cards into finished quantities ready for shipping.
At the heart of Rollem’s current range is a compact ABB controller called NextMove-ESB2. This packaged module is capable of controlling up to eight servo and stepper motor axes, and includes on-board analogue and digital I/O for general machine control, plus interfaces including a CANopen port for controlling distributed motion and I/O resources.
Depending on the particular finishing line configuration and number of motion axes, one or more controller is installed in the distributed control system. ABB’s architecture provides Rollem with a granular control solution that scales economically according to the complexity of the required finishing line. NextMove’s broad combination of motion and machine control functionality also gives it great versatility to meet the needs of any particular new station in Rollem’s expanding modular equipment family.
The newly-designed descending card stacker is typically installed as a third station on a Rollem print finishing line, following slitting and collating stations. This peripheral employs a single axis of movement using a stepper motor, which dynamically varies the height of a stacking tray that is synchronised to a laser sensor detecting the position and height of printed items. In the case of playing card printing for instance, the system can group multiple packs to create a ready-to-use Blackjack deck. In the business card world, the system will group specific printed quantities such as 250 or 500 into a stack for final shipping.
Designing and integrating this new modular peripheral was simplified by the ABB motion control system. The stepper motor axis and its ABB drive connects to the main controller and HMI via the print finishing line’s CANopen network. Software-wise, the nature of ABB’s MINT motion software language made it easy for the Rollem developers to create code, as it uses clear English-like commands and has hundreds of keywords that provide single-command instructions for motion tasks. One of the most common keyword forms used by Rollem is a set of commands called FOLLOW for example, which allow axes to be linked and follow a master axis by a programmed ratio.
In the case of the new stacker, Rollem’s main software developer Stuart Murphy wrote the control code and the additional code required for the machine’s HMI in less than half a day, before testing it on the prototype electromechanical hardware.
IPE Newsletter
IPE publishes a weekly eNewsletter, delivering a carefully chosen selection of the latest stories straight to your inbox.
Subscribe here